Contact us
If you are interested in cooperation, please contact us immediately, we will give you feedback as soon as possible!


03
2026
-
11
Looking for an Alternative to SMC Electric Grippers? A Selection Checklist
Author:
Engineers often search for an alternative to an SMC electric gripper when they need a second source, a different interface or a shorter delivery. This checklist lists what to compare: stroke, grip force, controller and I/O, lead time and support, and maps each requirement to W-ROBOT models with data from our selection manual.
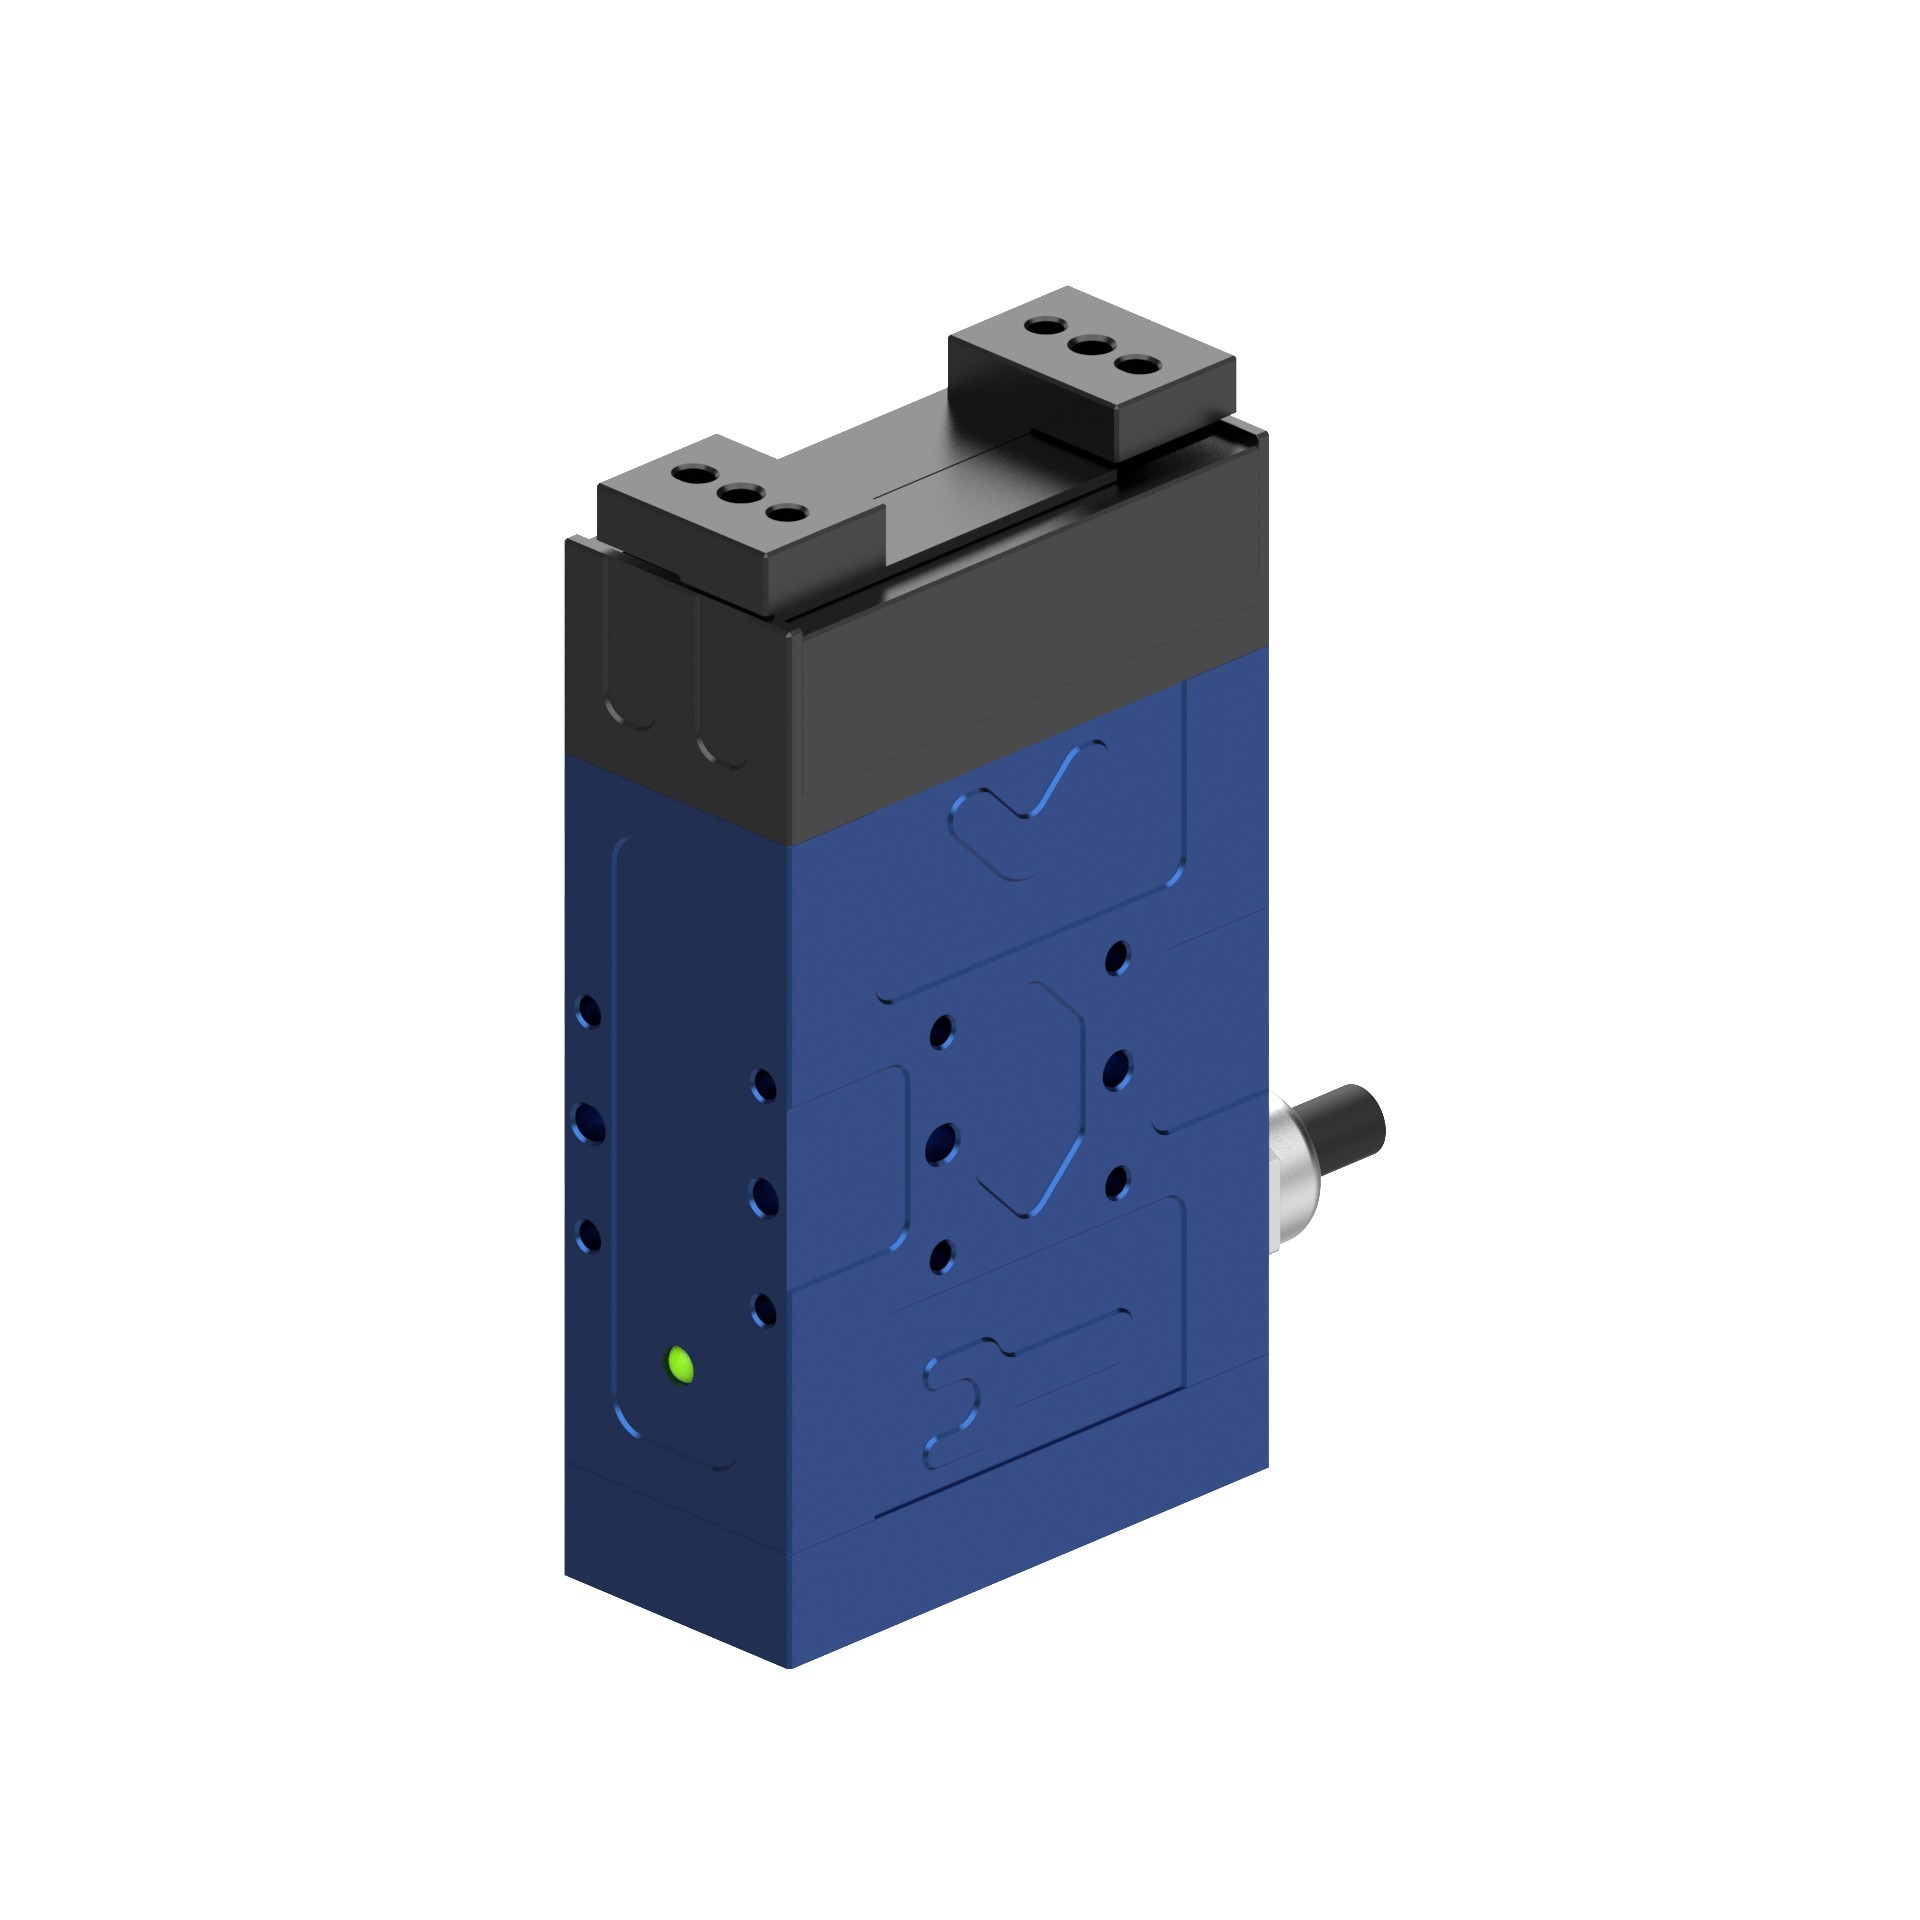
SMC is a well-known brand of pneumatic and electric actuators, and many machine builders start their gripper design from its catalog. When a project needs a second source, a different control interface or a different delivery schedule, engineers search for an "SMC electric gripper alternative". This page does not compare brands. It gives you a checklist of what to compare in any electric gripper, and shows which W-ROBOT models to look at for each requirement, using values from our own selection manual.
1. Start from your application, not from a part number
Cross-referencing part numbers between brands rarely works one-to-one, because stroke definitions, force ranges, mounting patterns and interfaces differ. Write down the application data first:
- Part size range at the gripping point, and part mass.
- Maximum acceleration, including emergency stops.
- Required cycle time for one open/close move.
- Control method on your PLC or robot: digital I/O or fieldbus.
- Mounting space, cable exit and the existing flange or adapter plate.
- Environment, and whether the gripper is mounted on a cobot.
2. The selection checklist
Stroke
Required stroke ≈ maximum part size − minimum part size + clearance on both sides. Check how the data sheet defines stroke (total travel or single-finger travel); each W-ROBOT parameter page states the definition, for example EPG3 lists a single-finger stroke.
Grip force
Calculate the force from mass, acceleration, friction and a safety factor, then check that it falls inside the gripper's continuous grip force range, not only below its maximum. Our electric gripper sizing guide gives the formula and a worked example.
Controller and I/O
Check whether the controller is built in or external, the supply voltage, and the interface. Simple open/close stations can use I/O; stations that change force or position per part need a fieldbus. The W-ROBOT models in the table below run on DC24V ±10% with a built-in controller.
Lead time
Ask for the lead time per model and quantity, for samples as well as series orders, and get it in writing on the quotation. At W-ROBOT the lead time is confirmed on each quotation.
Support and documentation
Check that you can get a parameter page, a 3D model, wiring and communication documentation, and an engineer who will review your sizing before you order.
3. Map your requirement to a W-ROBOT model
| Requirement | W-ROBOT model | Stroke | Continuous grip force | Open/close (one way) | Interface |
|---|---|---|---|---|---|
| Small parts, open/close only, replacing a 16 mm-bore air gripper | EPGS-6-10 (16D) | 6 mm | 10 N ±20% | 0.1 s | I/O |
| Precision 2-finger pick-and-place | EPG2-26-15 / EPG2-26-50 | 0–26 mm | 6–15 N / 15–50 N | 0.3 s | Modbus RTU (RS485) + I/O |
| Wider parts, 2-finger | EPG2-50-50 | 0–50 mm | 15–50 N | 0.5 s | Modbus RTU (RS485) + I/O |
| Round or irregular-shaped parts | EPG3-10-50 (3-finger centric) | 0–10 mm (single finger) | 15–50 N | 0.1 s | Modbus RTU (RS485) + I/O |
| Cobot end-of-arm tooling | EPGC-50-150 | 50 mm | 40–150 N | 0.5 s | Modbus RTU (RS485) + I/O |
| Grip and rotate in one unit | ERG-20-80 | 20 mm | 24–80 N | 0.2 s | Modbus RTU (RS485) + I/O |
| Large, heavy parts | EPGL-150-1200 | 0–150 mm | 360–1200 N | 1.5 s | EtherCAT |
Source: W-ROBOT Electric Gripper Selection Manual (2026-08 edition), parameter pages. Repeatability: ±0.1 mm for EPGS-6-10; ±0.02 mm for EPG2-26-15, EPG2-26-50, EPG2-50-50, EPG3-10-50, EPGC-50-150, ERG-20-80 and EPGL-150-1200.
For rotary applications read the rotating gripper guide. For cobots, see electric grippers for collaborative robots. The full range is on the electric gripper page.
4. Common mistakes when changing gripper supplier
- Matching only the maximum grip force and ignoring the minimum: a light part may need a gripper whose adjustable range starts low enough.
- Forgetting the fingertips: new fingers, a new adapter plate and the tool centre point must be designed and checked.
- Assuming the same I/O logic: signal names, in-position and drop detection outputs, and fieldbus registers need to be mapped again in the PLC program.
- Skipping the cycle-time check: compare the open/close time of the new model with your takt time, not only stroke and force.
5. Test before you switch
- Send us the part drawing, mass, cycle time and your current interface.
- A W-ROBOT engineer proposes a model and checks stroke, force and mounting.
- Test a sample on the real station: grip, release, drop detection and cycle time where the model supports them.
- Confirm fingertips, cable and adapter plate, then the series order and lead time.
If you are moving from air grippers at the same time, read electric vs pneumatic grippers. Ready to compare? Request a quote or contact our engineers.
SMC is a trademark of its respective owner. W-ROBOT is not affiliated with SMC Corporation. The brand name is used only to describe what engineers search for; this page makes no statement about SMC products.
FAQ
Is W-ROBOT a drop-in replacement for SMC electric grippers?
We do not claim one-to-one interchangeability. Stroke definitions, mounting and interfaces differ between brands, so we select a W-ROBOT model from your application data and check the mounting and interface with you.
Which W-ROBOT electric gripper should I look at first?
For open/close only, the EPGS series with I/O. For precision pick-and-place, EPG2. For cobots, EPGC-50-150. For grip-and-rotate, ERG. For large parts, EPGL-150-1200.
What control interfaces do W-ROBOT electric grippers support?
EPGS models use I/O. EPG2, EPG3, EPG4, EPGC and ERG models support Modbus RTU (RS485) and I/O. EPGL-150-1200 uses EtherCAT.
What is the lead time for a W-ROBOT electric gripper?
It depends on the model, configuration and quantity, and is confirmed on the quotation.
Can I test a sample before switching?
Send us your project details and our sales team will review a sample arrangement.
electric gripper alternative, selection checklist, EPGS, EPG2, EPGC, ERG, EPGL

HIGH-TECH ENTERPRISE
AUTOMATED PRODUCTION
Contact Us
> Whatsapp: +86 13360462722
> Email: [email protected]
> Address: 9th Floor, Zone C, Songhu Zhigu
Industrial Building, No. 9 Yanhe South Road, Liaobu
Town, Dongguan City
China Site: wrobot.top · Linear Module Factory & Online Quote
China Site: wrobot.top · Linear Module Factory & Online Quote
Copyright © 2025 ShenZhen W-Robot Industry Co.,Ltd. All Rights Reserved.